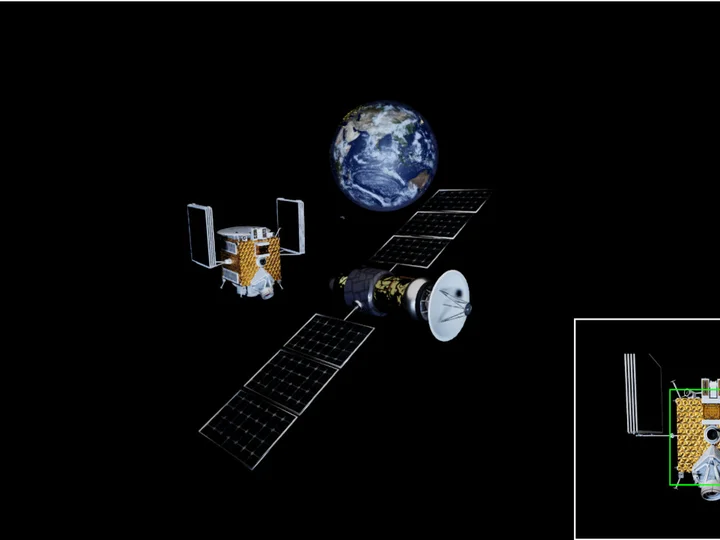
The increasing density of orbital debris elevates collision risk and drives the need for autonomous systems capable of operating under strict safety and sustainability constraints. The Space Robotics and Sustainability (SRS) architecture introduces the PAG AI framework to embed regulatory compliance directly within the maneuver-selection loop, enabling reliable, delay-tolerant, and policy-compliant Autonomous Orbital Operations.
Ensures dynamically consistent behavior by grounding perception, state estimation, and trajectory generation in realistic orbital dynamics and physical control constraints.
Structures the decision-making process through distributed, modular agents that manage specific operational roles, enabling coordinated and traceable autonomous actions.
Translates international sustainability and debris mitigation frameworks into enforceable operational constraints that regulate maneuver admissibility.
Detailed capabilities and technical specifications developed for this mission.
Evaluates candidate maneuvers using multi-criteria indicators, balancing mission safety, propulsion efficiency, regulatory compliance margins, and time performance.
Prioritizes agent activation based on current mission context, uncertainty, and risk contribution, ensuring resource-aware computational coordination.
Maintains autonomous, policy compliant decision-making during communication gaps, ensuring safe continuous operations without constant ground supervision.
Generates structured logs of system states, candidate maneuvers, evaluations, and governance filtering outcomes for complete post-mission auditing and human-in-the-loop oversight.
Organizes the system from raw sensing and trajectory prediction up to ethics, learning, and simulation, creating a robust perception-to-action pipeline.
Provides a system-level evaluation metric aggregating mission success, risk performance, propulsive efficiency, and decision reproducibility to benchmark overall orbital sustainability.